Yocto Linux BSP Ver.A User Guide for iMX8 series -Yocto 3.0
Contents
- 1Getting Started 1.1Building Yocto Image System Requirements 1.2Conventions 1.3Docker install and setting 1.3.1To install Docker Engine on your platform 1.3.2To pull ubuntu 18.04 image from Docker Hub 1.3.3To create container 1.4Get BSP 1.4.1Download_BSP_From_GitHub 1.4.2Copy BSP tarball to Container 1.5Downloads tarball 1.6Introducing BSP 1.6.1Naming Rule 1.6.2BSP Content 1.7Build Instructions 1.7.1To create one new build environment 1.7.2To continue an exist build environment 1.7.3To build sdcard image 1.7.4To build toolchain installer 1.7.5To build bootloader 1.7.6To build linux kernel 1.8Creating boot-up on-board flash from prebuilt image 1.8.1To create one boot-up SD card 1.9Creating boot-up on-board flash from built sdcard image 1.9.1To create one boot-up SD card 1.10Debug console information 1.10.1Preparing for processors device 1.10.2Preparing for software tool 1.11One step build image
- 2Customization 2.1Package addition 2.1.1To add tcf-agent & openssh-sftp-server 2.1.2To add chromium browser 2.1.3To add QtWebEngine 2.2Setting up SDK 2.3Setting up cross compiling environment 2.4Build U-Boot in standalone environment 2.4.1Config u-boot 2.4.2Build u-boot 2.5Build imx-boot image by using imx-mkimage 2.5.1Replace imx-boot 2.6Building & updating kernel/modules/dtb manually 2.6.1Copy BSP tarball to Container 2.6.2Config kernel 2.6.3Replace kernel & dts 2.7Improve boot speed
- 3System Recovery
- 4Package List
- 5Device Tree Source file select 5.1ROM-5721 5.2ROM-5720 5.3ROM-5620 5.4ROM-7720 5.5RSB-3720 5.6ROM-5722 5.7ROM-3620 5.8RSB-3730
- 6Burn-in Test
- 7About bottom board setting 7.1The disable pin of PCIE 7.2Fix no sound issue probability when the HDMI plug in/out
- 8How to get the MAC, Serial Number, and Manufacture Date in the QSPI flash
Getting Started
Building Yocto Image System Requirements
- CPU Cores: Quad-core processor (or higher recommended)
- Memory: 8GB RAM (more is recommended for better performance)
- Disk Space: 350GB (more is recommended and SSD is suggested for better performance)
Conventions
${PREBUILT_IMAGE} : compressed prebuilt image (*.img.gz)
${CONTAINER_NAME} : container name (e.g. imx8LBVA0016)
${BSP_TARBALL} : BSP tarball (*.tgz)
${BSP_HOME} : home directory of the BSP
${BDIR} : build directory (e.g. build_x11)
${MX8PROC} : i.MX8 Processor
mx8mq for iMX8M Dual Core mx8mm for iMX8MM mx8mp for iMX8MP mx8qm for iMX8QM mx8qxp for iMX8QXP
${IMX8PROC} : i.MX8 Processor
imx8mq / imx8mm / imx8qm /imx8qxp /imx8mp
${BOARD} : available target boards list below
rom5720 rom5721 rom7720 rom5620 rom3620 rom5722 rsb3720 epcr5710 rsb3730
${BOARD_REV} : board revision
a1
${MC} : machine code combined with ${IMX8PROC}${BOARD}${BOARD_REV}
for example,
imx8mqrom5720a1 for ROM-5720 A1
imx8qmrom7720a1 for ROM-7720 A1
imx8qxprom5620a1 for ROM-5620 A1
imx8qxprom3620a1 for ROM-3620 A1
imx8mmrom5721a1 for ROM-5721 A1
imx8mprom5722a1 for ROM-5722 A1
imx8mprsb3720a1 for RSB-3720 A1
imx8mpepcr5710a1 for EPC-R5710 A1
imx8mmrsb3730a2 for RSB-3730 A2
You can also use the command below to check supported machines on BSP
$ source setup-environment
${MEM_SIZE} : memory size
2G/4G
${UC} : u-boot config
1G/2G/4G/FSPI_1G/FSPI_2G...
${SD_DEVICE} : device name of SD card in Linux (e.g. /dev/sdf)
${SDCARD_IMAGE} : sdcard image built by bitbake (VA0033 ~ VA0362: *.wic.bz2; VA0386 ~ latest version: *.sdcard)
${WORKSPACE} : host workspace folders
${UBOOT} :u-boot version(e.g. 2016.03)
${KERNEL} : linux kernel version(e.g. 4.14.98)
${TOOLCHAIN} : toolchain installed directory(e.g. /opt/fsl-imx-x11/4.1.15-2.0.0)
debug console / serial console
serial terminal program (e.g. minicom, putty, teraterm ...) that serial port is configured to 115200 8N1
terminal console
terminal program (e.g. gnome-terminal, xfce4-terminal ...)
Docker install and setting
If you don't have docker in your system, then you can follow the below steps to install docker and run it first.
To install Docker Engine on your platform
Please refer to Docker Installation Guide for details
To pull ubuntu 18.04 image from Docker Hub
$ docker pull advrisc/u18.04-imx8lbv1
To create container
$ docker run --privileged -it --name ${CONTAINER_NAME} -v ${WORKSPACE}:/home/adv/adv-release-bsp -v /dev:/dev -v /lib/modules:/lib/modules -v /usr/src:/usr/src advrisc/u18.04-imx8lbv1 /bin/bash
Get BSP
You have two methods to put BSP into container created above
Download_BSP_From_GitHub
The following example shows how to download the Advantech Yocto BSP from GitHub. For this example, a directory called adv-release-bsp is created for the project. Refer to IoTGateway/BSP/Linux/iMX8/OS_Support_List , Official version " imx8LBVA0209" is taken as an example :
$ git config --global user.name "Your Name"
$ git config --global user.email you@example.com
$ sudo chown adv:adv adv-release-bsp
$ cd adv-release-bsp
$ repo init -u git://github.com/ADVANTECH-Corp/adv-arm-yocto-bsp.git -b imx-linux-zeus -m imx8LBVA0428.xml
$ repo sync
If you want to get latest bsp
$ repo init -u git://github.com/ADVANTECH-Corp/adv-arm-yocto-bsp.git  -b imx-linux-zeus -m imx-5.4.70-2.3.0.xml
$ repo sync
If you suffer "server certificate verification failed", you can use the following command to disable SSL verification in git repositories with self-signed certificates.
$ export GIT_SSL_NO_VERIFY=1
or
$ git config --global http.sslverify false
If you get "The unauthenticated git protocol on port 9418 is no longer supported.", you can try it.
$ git config --global url."https://".insteadOf git://
Important : As of March 31, 2023, all source repositories have been migrated to other platforms and the project has been shut down. ** Repo sync will be fail. Solution : (1) If you repo current xml file, repo sync is success. Example:
$ repo init -u [git://github.com/ADVANTECH-Corp/adv-arm-yocto-bsp.git git://github.com/ADVANTECH-Corp/adv-arm-yocto-bsp.git] <span>-b imx-linux-zeus -m </span>imx-5.4.70-2.3.0.xml
(2) If you repo tag version xml file, please follow " Yocto3.0_Repo_Fail_SOP " to modify XML File. Example:
$ repo init -u git://github.com/ADVANTECH-Corp/adv-arm-yocto-bsp.git -b imx-linux-zeus -m imx8LBVA0428.xml <- Tag XML
Copy BSP tarball to Container
If you have BSP tarball (eg. imx8LBVA0029_2019-10-23.tgz), then you have to copy it into container.
Follow the steps below:
1.Exit container and back to local machine
$ exit
2.Copy BSP tarball to ${WORKSPACE} , and change owner
$ cp imx8LBVA0029_2020-10-23.tgz ${WORKSPACE}
$ sudo chown adv:adv ${WORKSPACE}/imx8LBVA0029_2020-10-23.tgz
3.Back to container
$ docker start ${CONTAINER_NAME}
$ docker attach ${CONTAINER_NAME}
4.Unpack BSP tarball
$ tar zxvf imx8LBVA0029_2020-10-23.tgz
Downloads tarball
Not necessarily step During building Yocto image , it will generate downloads folder which includes all packages we need , but it usually can't fetch normally, so we keep this downloads folder. Then we can reduce some fetch failed issue. You can get Downloads tarball (downloads_imx8_5.4.24.tar.gz) or (downloads_imx8_5.4.70.tar.gz) from following URL: [downloads_imx8_5.4.24.tar.gz ], md5 checksum: 648a6aa9d03be61ee21611b729250319 [downloads_imx8_5.4.70.tar.gz ], md5 checksum: ec2a0da745e57329a73965f9bd7ff0c9 If you get downloads tarball, you can copy to your ${WORKSPACE}
Follow the steps below:
1.Exit container and back to local machine
$ exit
2.Copy Downloads tarball to ${WORKSPACE} , and change owner
$ cp downloads_imx8_5.4.24.tar.gz ${WORKSPACE}
$ sudo chown adv:adv ${WORKSPACE}/downloads_imx8_5.4.24.tar.gz
3.Back to container
$ docker start ${CONTAINER_NAME}
$ docker attach ${CONTAINER_NAME}
4.Unpack Downloads tarball
$ tar zxvf downloads_imx8_5.4.24.tar.gz
5.make link to downloads folder
$ cd adv-release-bsp
$ ln -s ${WORKSPACE}/downloads_imx8_5.4.24 downloads
Introducing BSP
The BSP is based on Yocto Project with Freescale enhanced features for i.MX8, plus specific target board features from Advantech Inc.. The Advantech Yocto Project BSP Release directory contains a "sources" directory, which contains the recipes used to build,
one or more build directories, and a set of scripts used to set up the environment.
The recipes used to build the project come from both the community and Advantech. The Yocto Project layers are downloaded
to the sources directory. This sets up the recipes that are used to build the project.
Naming Rule
The tarball/prebuilt image name is consist of the model name followed by "LB" or "LI" plus version number and released date. For example, BSP file name: imx8LBVA0010_2019-08-27.tgz which , "LB" is acronym of L inux B 20191025 Package Version List "VA0010" stands for V ersion A . 0010 . For example, Yocto image name: ' 5720A1AIM20LIVA0010_iMX8M_2G_2020-08-27.img.gz' which "5720A1" stands for ROM-5720 A1 "LI" is acronym for prebuilt L inux I mage "2G" is DDR size
BSP Content
The description of some important folders list below: sources/ meta-advantech/ : meta layer by Advantech meta-fsl-*/ : meta layer by Freescale fsl-setup-release.sh : to create one new build environment setup-environment : to continue an exist build environment
Build Instructions
To create one new build environment
Perform the following commands in terminal console
$ cd ${BSP_HOME}
$ MACHINE=${MC}
DISTRO=fsl-imx-xwayland
source imx-setup-release.sh -b ${BDIR}
We can specify u-boot default config like below
$ MACHINE=${MC}
UBOOT_CONFIG=${UC}
DISTRO=fsl-imx-xwayland
source imx-setup-release.sh -b ${BDIR}
Example : MACHINE=imx8mmrsb3730a1 UBOOT_CONFIG=2G DISTRO=fsl-imx-xwayland source imx-setup-release.sh -b 3730
You need to read and accept the EULA.

To continue an exist build environment
Perform the following commands in terminal console
$ cd ${BSP_HOME}
$ source setup-environment ${BDIR}
To build sdcard image
To create/continue a build environment
Perform the following command in terminal console
$ bitbake imx-image-full
The file, imx-image-full-
${MC}
.wic.bz2 or VA0386 ~ latest version: imx-image-full-
${MC}
.rootfs.sdcard, will be located in directory, ./tmp/deploy/images/
${MC}
, while building process finished successfully.
To build toolchain installer
To create/continue a build environment
Perform the following command in terminal console
$ bitbake meta-toolchain
The below installer will be located in the directory "./tmp/deploy/sdk".
fsl-imx-xwayland-glibc-x86_64-meta-toolchain-aarch64-toolchain-
${KERNEL}
-zeus.sh
To build bootloader
To create/continue a build environment
Perform the following command in terminal console
$ bitbake imx-boot
To build linux kernel
To create/continue a build environment
If you operate on docker images, please install tmux application before running this command
$ sudo apt-get install tmux
Type following command to enter tmux
$ tmux
Perform the following command in terminal console to show up menuconfig
$ bitbake linux-imx -c menuconfig
After edit menuconfig, type following command to exit tmux windows
$ exit
to build kernel image
$ bitbake linux-imx
The two files, Image & Image-
${IMX8PROC}
${BOARD}
${BOARD _REV } .dtb, will be located in the directory, ./tmp/deploy/images/ ${MC} .
Creating boot-up on-board flash from prebuilt image
To create one boot-up SD card
Perform the following command in terminal console
# gunzip -c ${PREBUILT_IMAGE} | dd of=${SD_DEVICE} bs=1M
# sync
Creating boot-up on-board flash from built sdcard image
To create one boot-up SD card
Perform the following commands in terminal console
$ pushd ${BSP_HOME}/${BDIR}/tmp/deploy/images/${MC}
$ sudo bzcat ${SDCARD_IMAGE} | sudo dd of=${SD_DEVICE} bs=1M
(VA0033 ~ VA0362)
$ sudo cat ${SDCARD_IMAGE} | sudo dd of=${SD_DEVICE} bs=1M
(VA0386 ~ latest version)
$ sync
$ popd
Note : ues the .sccard file.
Debug console information
If you want to see debug message from device, you need to prepare for processors device and software tool.
Preparing for processors device
- The following URL provides information about the debug port slot and the debug port line for each device
Debug Port Information
Preparing for software tool
- You need to prepare the debug console tool. For example: "minicom" tool or "putty" tool.
- Baud rate: 115200
One step build image
Our machine must be pre-installed docker
Download the following script can quickly build our image.
$ wget https://raw.githubusercontent.com/ADVANTECH-Corp/RISC_tools_scripts/zeus/imx8/adv_imx8_build.sh
$ sudo chmod a+x adv_imx8_build.sh
Build image
$ sudo ./adv_imx8_build.sh ${BOARD}
$ sudo ./adv_imx8_build.sh rom5720
Our image will be in workspace folder.
workspace/${BDIR}/tmp/deploy/images/${MC}
Then refer to Creating_boot-up_on-board_flash_from_built_sdcard_image to build SD card.
Customization
Package addition
To add tcf-agent & openssh-sftp-server
Navigate to the directory where fsl-image-adv.inc located
$ cd ${BSP_HOME}/sources/meta-advantech/meta-fsl-imx/recipes-fsl/images
Add following line to fsl-image-adv.inc
IMAGE_INSTALL += " tcf-agent openssh-sftp-server "
Continue an exist build environment
and
build sdcard image
To add chromium browser
Navigate to the directory where local.conf located
$ cd ${BSP_HOME}/${BDIR}/conf
- Method 1(Suggest): Add following one line to local.conf
CORE_IMAGE_EXTRA_INSTALL += "chromium-ozone-wayland"
- Method 2: Add following two lines to local.conf
IMAGE_INSTALL_append = \
   "${@bb.utils.contains('DISTRO_FEATURES', 'wayland', ' chromium-ozone-wayland libexif', \
       bb.utils.contains('DISTRO_FEATURES',     'x11', ' chromium-x11 libexif', \
                                                        , d), d)}"
LICENSE_FLAGS_WHITELIST = \
   "${@bb.utils.contains('DISTRO_FEATURES', 'wayland', 'commercial', \
       bb.utils.contains('DISTRO_FEATURES',     'x11', 'commercial', \
                                                       , d),"
Continue an exist build environment and build sdcard image
To add QtWebEngine
Put the following in
${BSP_HOME}
/
${BDIR
}
/conf/local.conf
IMAGE_INSTALL_append += "packagegroup-qt5-webengine"
Continue an exist build environment
and
build sdcard image
Setting up SDK
Please follow the section,
To build toolchain installer
, to build one toolchain installer
Perform the following command in terminal console
$ cd ${BSP_HOME}/${BDIR}/tmp/deploy/sdk
$ sudo ./fsl-imx-xwayland-glibc-x86_64-meta-toolchain-aarch64-toolchain-5.4-zeus.sh
Enter new installed directory or just press
Enter
to use default directory.
While
Proceed[y/n]?
shows up, please enter the correct one.
Waiting for the SDK installed (while the following messages show up completely)

Setting up cross compiling environment
SDK has been set up (ref.
Setting up SDK
)
Perform the following command in terminal console
$ source ${TOOLCHAIN}/environment-setup-aarch64-poky-linux
Build U-Boot in standalone environment
Config u-boot
make ${IMX8PROC}_${BOARD}${BOARD_REV}_${MEM_SIZE}_defconfig
eg.
make imx8mm_rom5721a1_2G_defconfig
Build u-boot
make -j4
Build imx-boot image by using imx-mkimage
Get imx-boot tarball from our server Here we take rom5721 as an example:
tar zxvf 5721A1AIM20LIVA0118_iMX8MM_imx-boot.tgz
cd 5721A1AIM20LIVA0118_iMX8MM_imx-boot/
In this folder , we have two script as below: Copy necessary files to imx-mkimage folder
./cp_uboot.sh ${uboot path} ${IMX8PROC}
Make imx-boot image
./mk_imx-boot.sh ${IMX8PROC}
eg.
./cp_uboot.sh ../uboot-imx6 imx8m
./mk_imx-boot.sh imx8mm
Replace imx-boot
Perform the following command to transfer to on-board flash
$ dd if=flash.bin of=/dev/mmcblk0 bs=1K seek=<offset> conv=fsync
Where offset is: 33 - for i.MAX 8QuadMax A0, i.Mx 8QuadXPlus A0, i.MX 8M Quad, and i.MX 8M Mini 32 - for iMX 8M PLUS, i.MAX 8QuadXPlus B0/C0 and i.Mx 8QuadMax B0
Building & updating kernel/modules/dtb manually
The cross compiling environment has been set up. (ref. Setting up cross compiling environment )
Copy BSP tarball to Container
Refer to Copy_BSP_tarball_to_Container, copy kernel tarball to ${WORKSPACE} and back to container
change owner & unpack tarball
$ sudo chown adv:adv imx8LBVA0029_2019-10-23_linux-imx.tgz
$ tar zxvf imx8LBVA0029_2019-10-23_linux-imx.tgz
Config kernel
Configure linux kernel
$ cd linux-imx
$ make distclean
$ make imx_v8_adv_defconfig
$ make menuconfig
Start building linux kernel
$ make -j4 Image
When you get error like below
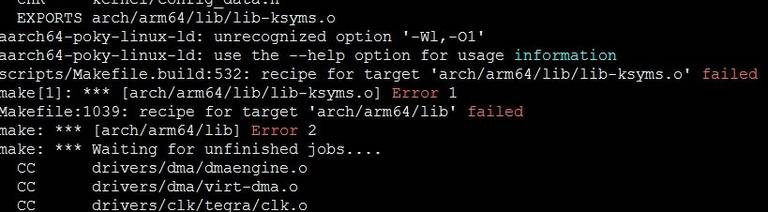
run command then rebuild
$ unset LDFLAGS
The kernel image file, Image, is located in the directory "./arch/arm64/boot/". Start building kernel modules
$ make -j4 modules
Copy all modules to a temporary rootfs directory, "~/temp/rootfs"
$ make modules_install INSTALL_MOD_PATH=~/temp/rootfs
Building device tree blob
$ make -j4 freescale/${IMX8PROC}-${BOARD}-${BOARD_REV}.dtb
eg.
$ make -j4 freescale/imx8mq-rom5720-a1.dtb
The device tree blob, ${IMX8PROC}
${BOARD}
${BOARD_REV} .dtb, is located in the directory "./arch/arm64/boot/dts/freescale/".
Replace kernel & dts
Replace kernel copy Image to SDcard or emmc Replace dtb file copy dtb file to SDcard or emmc
Improve boot speed
- Bootloader
1.bootdelay time
We can cancel the bootdelay time by setting bootloader environment value.
setenv bootdelay 0
env save
reset
2.Disable console
Disable debug message output can also improve boot speed
Disable kernel message
setenv mmcargs setenv bootargs ${jh_clk} console=${console} modprobe.blacklist=${modprobe.blacklist} root=${mmcroot} video=HDMI-A-1:${videores} quiet
env save
reset
Or
Disable debug port
(1) Yocto machine setting:
modify /sources/meta-advantech/meta-fsl-imx/conf/machine$/${MC}.conf
SERIAL_CONSOLES = ";"
(2) Uboot parameter setting:
- For the imx8mq, imx8mm, imx8mp:
setenv console disabled
env save
reset
- For the imx8qm, imx8qxp:
setenv console disabled
setenv earlycon disabled
setenv mmcargs setenv bootargs console=${console},${baudrate} earlycon=${earlycon},${baudrate} root=${mmcroot}
env save
reset
- Rootfs
TBD
- Services
- Using systemctl disable remove ,we can remove unnecessary services.
systemctl disable <services>
eg.
systemctl disable boottimes
System Recovery
This section provides detail procedures of restoring the eMMC image.
If you destroy the onboard flash image by accident, you can recover a system following these steps.
- Recovery by SD card
1.Copy 5720A1AIM20LIVA0022_iMX8M_flash_tool.tgz package to your desktop.
2.Insert SD card to PC
3.Make a bootable sd card
# tar zxvf 5720A1AIM20LIVA0022_iMX8M_2G_flash_tool.tgz
# cd 5720A1AIM20LIVA0022_iMX8M_2G_flash_tool/mk_inand/
# sudo ./mksd-linux.sh /dev/sdg
4.Insert SD card and copy 5720A1AIM20LIVA0022_iMX8M_flash_tool to USB disk
5.Insert USB disk and SD card then Boot from SD
6.Enter usb disk folder, make a bootable emmc
# cd /run/media/sda1/
# cd 5720A1AIM20LIVA0022_iMX8M_2G_flash_tool/mk_inand/
# sudo ./mksd-linux.sh /dev/mmcblk0
- Recovery by UUU tool
1.Download uuu tool from ( https://github.com/ADVANTECH-Corp/uuu/releases/tag/v20210429 )
2.burn command
- For Linux
sudo ./uuu
- For Windows
uuu.exe
2.Create a folder with files as below:
1.uuu
2.imx-boot-imx8mqrom5720a1-sd.bin-flash_evk
3.fsl-image-validation-imx-imx8mqrom5720a1-20190917152605.rootfs.sdcard
4.Image_dtb.uuu
5.rootfs.uuu
3.Connect otg cable from PC to device
4.Set the correct boot mode(ROM-5722/ROM5720/ROM5721/ROM5620: 1,2,3-off 4-on, ROM7720: 1,2,3,4,5,6-off or 1,2,4,5,6-off 3-on), then power on
5.Perform the following command:
PS.If you want to burn uboot to mmcblk0 instead of mmcblk0boot0, u-boot must be updated to version 20191101,
1.Burn uboot to emmc
   a)replace uboot in mmcblk0boot0
       sudo ./uuu -b emmc imx-boot-imx8mqrom5720a1-sd.bin-flash_evk
   b)replace uboot in mmcblk0
       sudo ./uuu -b emmc_adv imx-boot-imx8mqrom5720a1-sd.bin-flash_evk
2.Burn rootfs image to emmc
   a)replace uboot in mmcblk0boot0
       sudo ./uuu -b emmc_all imx-boot-imx8mqrom5720a1-sd.bin-flash_evk fsl-image-validation-imx-imx8mqrom5720a1-20190917152605.rootfs.sdcard
   b)replace uboot in mmcblk0
       sudo ./uuu -b emmc_all_adv imx-boot-imx8mqrom5720a1-sd.bin-flash_evk fsl-image-validation-imx-imx8mqrom5720a1-20190917152605.rootfs.sdcard
6.uuu tool will start recovery image to emmc.
7.If we want to burn separately into emmc
   a)replace Image and dtb
       Step 1: rename Image and dtb
                 _Image
                 _board.dtb
       Step 2:
                 sudo ./uuu Image_dtb.uuu
   b)replace rootfs
       Step 1: rename rootfs tarball
                 _rootfs.tar.bz2
       Step 2:
                 sudo ./uuu rootfs.uuu
8.For more usage ( https://github.com/NXPmicro/mfgtools/wiki )
Package List
In BSP , list all packages which will be built in the image
bitbake -g imx-image-full && cat task-depends.dot | grep -v -e '-native' | grep -v digraph | grep -v -e '-image' | awk '{print $1}' | sort | uniq
20191025 Package List 20191025 Package List
Show all recipes (include non-installed packages)
bitbake -s
20191025 Package Version List
You can also check ${BDIR} /tmp/deploy/images/ ${MC} /fsl-image-qt5-validation-imx- ${MC} .manifest
It will show the same content with checking by rpm tool on target board.
On target board , list all packages by rpm tool
rpm -qa --root / --dbpath /var/lib/rpm | sort
20191025 RPM on Board List
Device Tree Source file select
We can setup different dts file on bootloader to enable different devices.
eg.
setenv fdt_file adv-imx8mm-rom5721-a1-dsi2dp.dtb
env save
boot
ROM-5721
- Display DSI to LVDS g070vw01 imx8mm-rom5721-a1.dtb g150xgel05 imx8mm-rom5721-a1-dsi2lvds-g150xgel05.dtb g215hvn01 imx8mm-rom5721-a1-dsi2lvds-g215hvn01.dtb DSI to DP imx8mm-rom5721-a1-dsi2dp.dtb DSI to HDMI imx8mm-rom5721-a1-adv7535.dtb DSI auog101uan02 imx8mm-rom5721-a1-auog101uan02.dtb
- M.2 SDIO Adjust CN43~CN48 imx8mm-rom5721-a1-m2-sdio.dtb
ROM-5720
- Display DSI to HDMI imx8mq-rom5720-a1-dcss-adv7535.dtb imx8mq-rom5720-a1-lcdif-adv7535.dtb For weston ui modify /etc/xdg/weston/weston.ini drm-device= card2 DSI auog101uan02 imx8mq-rom5720-a1-dcss-auog101uan02.dtb For weston ui modify /etc/xdg/weston/weston.ini drm-device= card2 Dual Display DSI to HDMI + HDMI imx8mq-rom5720-a1-dual-display.dtb For weston ui modify /etc/xdg/weston/weston.ini drm-device= card1
- M.2 SDIO Adjust CN43~CN48 imx8mq-rom5720-a1-m2-sdio.dtb
ROM-5620
- Display LVDS g070vw01 imx8mxp-rom5620-a1.dtb g150xgel05 imx8qxp-rom5620-a1-lvds-chimei.dtb g215hvn01 imx8qxp-rom5620-a1-lvds-dual.dtb LVDS to HDMI imx8qxp-rom5620-a1-hdmi-bridge.dtb DSI to HDMI imx8qxp-rom5620-a1-hdmi-bridge.dtb DSI auog101uan02 imx8qxp-rom5620-a1-auog101uan02.dtb
- M.2 SDIO Adjust CN43~CN48 imx8qxp-rom5620-a1-m2-sdio.dtb
ROM-7720
- Display HDMI imx8qm-rom7720-a1.dtb LVDS g070vw01 imx8qm-rom7720-a1-lvds0.dtb imx8qm-rom7720-a1-lvds1.dtb g215hvn01 imx8qm-rom7720-a1-lvds-dual.dtb HDMI + LVDS HDMI + g070vw01 imx8qm-rom7720-a1-hdmi-lvds0.dtb imx8qm-rom7720-a1-hdmi-lvds1.dtb HDMI + g215hvn01 imx8qm-rom7720-a1-hdmi-lvds-dual.dtb LVDS to HDMI imx8qm-rom7720-a1-it6263.dtb
- Audio Codec imx8qm-rom7720-a1-sgtl5000.dtb
RSB-3720
- Display HDMI (default) imx8mp-rsb3720-a1.dtb LVDS g070vw01(LVDS0) + HDMI imx8mp-rsb3720-a1-lvds0-auo.dtb g070vw01(LVDS1) + HDMI imx8mp-rsb3720-a1-lvds1-auo.dtb g215hvn01(DUAL LVDS) + HDMI imx8mp-rsb3720-a1-lvds-dual.dtb DSI adv7535(DSI to HDMI) + HDMI imx8mp-rsb3720-a1-adv7535.dtb auog101uan02(DSI) + HDMI imx8mp-rsb3720-a1-auog101uan02.dtb
- Camera OV5640 (default) imx8mp-rsb3720-a1.dtb Basler camrea imx8mp-rsb3720-a1-basler.dtb
ROM-5722
- Display HDMI (default) imx8mp-rom5722-a1.dtb LVDS g070vw01(LVDS0) + HDMI imx8mp-rom5722-a1-lvds0-auo.dtb g070vw01(LVDS1) + HDMI imx8mp-rom5722-a1-lvds1-auo.dtb g215hvn01(DUAL LVDS) + HDMI imx8mp-rom5722-a1-lvds-dual.dtb DSI adv7535(DSI to HDMI) + HDMI imx8mp-rom5722-a1-adv7535.dtb auog101uan02(DSI) + HDMI imx8mp-rom5722-a1-auog101uan02.dtb
- Camera OV5640 (default) imx8mp-rom5722-a1.dtb Basler camrea imx8mp-rom5722-a1-basler.dtb
ROM-3620
- Display LVDS g070vw01 imx8mxp-rom3620-a1.dtb g150xgel05 imx8qxp-rom3620-a1-lvds-chimei.dtb g215hvn01 imx8qxp-rom3620-a1-lvds-dual.dtb DSI to HDMI imx8qxp-rom3620-a1-hdmi-bridge.dtb DSI auog101uan02 imx8qxp-rom3620-a1-auog101uan02.dtb
RSB-3730
- Display HDMI imx8mm-rsb3730-a2.dtb LVDS g070vw01 imx8mm-rsb3730-a2-dsi2lvds-800x480.dtb g215hv01 imx8mm-rsb3730-a2-dsi2lvds-1920x1080.dtb DSI g101uan2.0 imx8mm-rsb3730-a2-dsi-auog101uan02.dtb
Burn-in Test
About bottom board setting
The disable pin of PCIE
You should config disable pin follow your bottom board.
&pcie0{

        pinctrl-names = "default";

        pinctrl-0 = <&pinctrl_pcie0>;

        //disable-gpio = <&tca9538 0 GPIO_ACTIVE_LOW>; <---

        reset-gpio = <&gpio1 13 GPIO_ACTIVE_LOW>;

        ext_osc = <1>;

        status = "okay";

};
Fix no sound issue probability when the HDMI plug in/out
You can use the following patch to fix this issue:
0001-imx865-hdmi-enable-overflow-workaround-for-imx865-hd.patch
From 9ca13642ff1367cb32c15f82d2c077f2f7c0e8f1 Mon Sep 17 00:00:00 2001

From: Sandor Yu <Sandor.yu@nxp.com>

Date: Mon, 25 Oct 2021 16:13:37 +0800

Subject: [PATCH] imx865: hdmi: enable overflow workaround for imx865 hdmi


Signed-off-by: Sandor Yu <Sandor.yu@nxp.com>

---

 drivers/gpu/drm/bridge/synopsys/dw-hdmi.c | 1 +

 1 file changed, 1 insertion(+)


diff --git a/drivers/gpu/drm/bridge/synopsys/dw-hdmi.c b/drivers/gpu/drm/bridge/synopsys/dw-hdmi.c

index b48cdaa493b7..b53e2efed3bf 100644

--- a/drivers/gpu/drm/bridge/synopsys/dw-hdmi.c

+++ b/drivers/gpu/drm/bridge/synopsys/dw-hdmi.c

@@ -2220,6 +2220,7 @@ static void dw_hdmi_clear_overflow(struct dw_hdmi *hdmi)

 	case 0x201a:

 	case 0x211a:

 	case 0x212a:

+	case 0x213a:

 		count = 1;

 		break;

 	default:

--

2.17.1
How to get the MAC, Serial Number, and Manufacture Date in the QSPI flash
MAC 0:
READ_DATA=`dd if=/dev/mtdblock0 bs=1 skip=$((0xd0000)) count=6 2> /dev/null | hexdump -e '16/1 "%02x " "\n"' | sed 's/ /:/g' | cut -c 1-17`

echo $READ_DATA
MAC 1:
READ_DATA=`dd if=/dev/mtdblock0 bs=1 skip=$((0xd0400)) count=6 2> /dev/null | hexdump -e '16/1 "%02x " "\n"' | sed 's/ /:/g' | cut -c 1-17`

echo $READ_DATA
Serial Number:
READ_DATA=`dd if=/dev/mtdblock0 bs=1 skip=$((0xd0006)) count=10 2> /dev/null | cut -c 1-10`

echo $READ_DATA
Manufacture Date:
READ_DATA=`dd if=/dev/mtdblock0 bs=1 skip=$((0xd0010)) count=14 2> /dev/null | cut -c 1-14`

READ_DATA=`echo $READ_DATA | cut -c 1-4`-`echo $READ_DATA | cut -c 5-6`-`echo $READ_DATA | cut -c 7-8`_`echo $READ_DATA | cut -c 9-10`-`echo $READ_DATA | cut -c 11-12`-`echo $READ_DATA | cut -c 13-14`

echo $READ_DATA